
Home > Robot Battery > Medical Robot Battery > 26650 48V 40Ah LiFePO4 Battery for Hotel Robotics with RS485
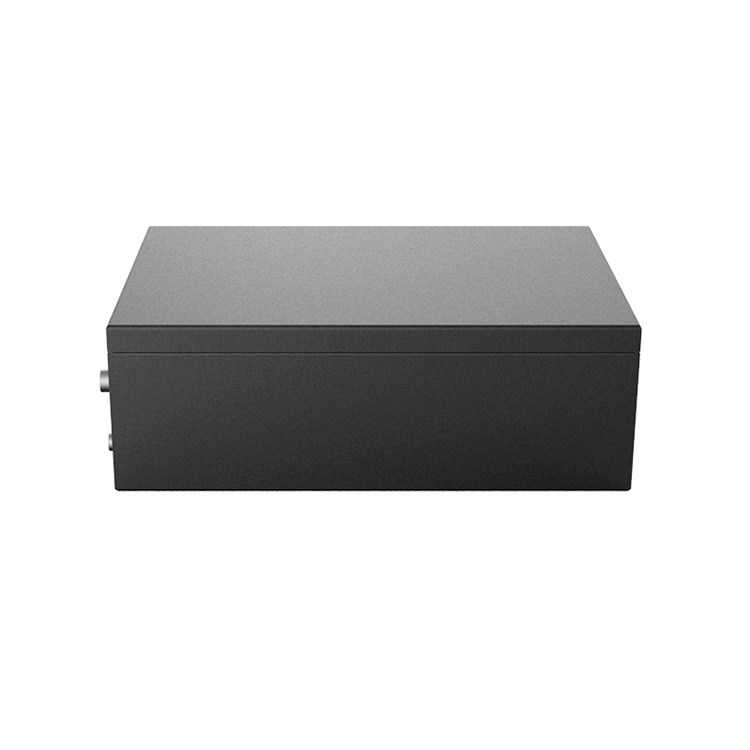
26650 48V 40Ah LiFePO4 Battery for Hotel Robotics with RS485
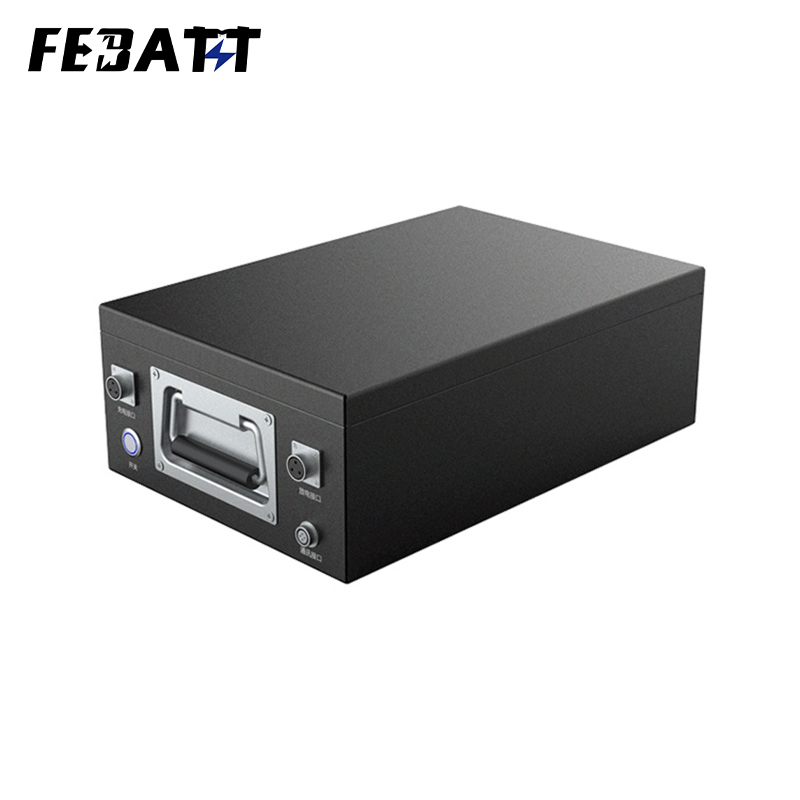
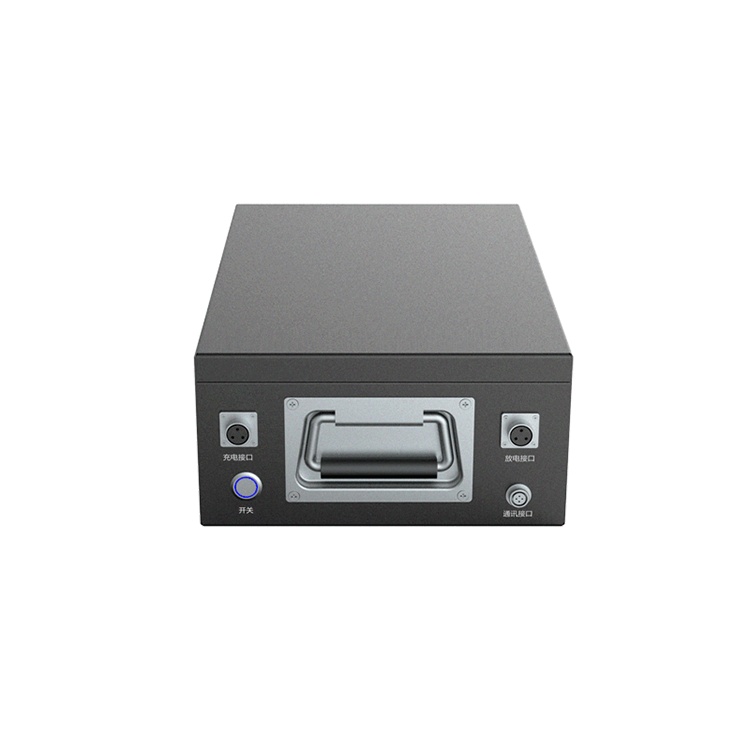
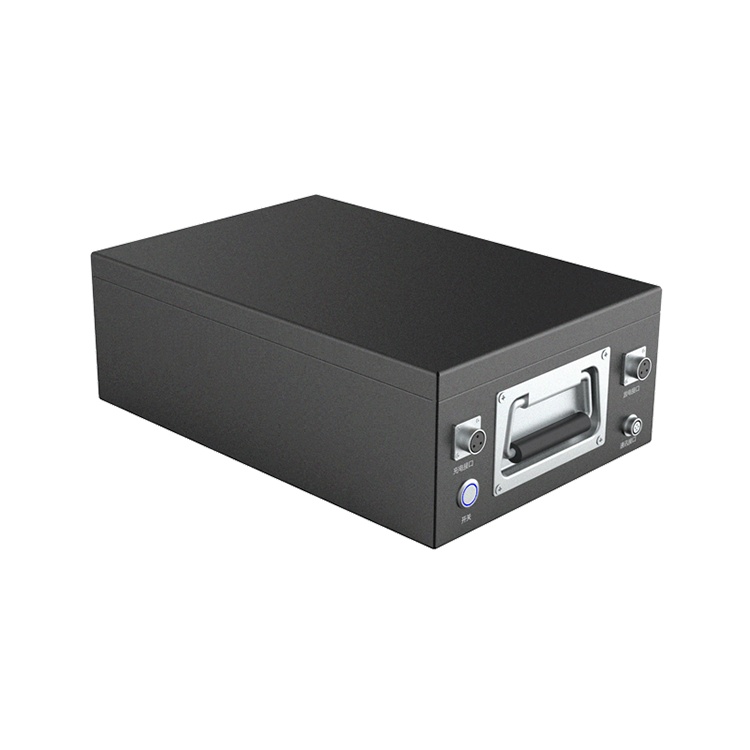
Battery for Hotel Robotics with RS485 delivers 48V power, RS485 communication, and LiFePO4 safety—ideal for hotel service robots, medical bots, and home automation machines.
- Nominal voltage:48V
- Nominal capacity:40Ah
- Charging voltage: 54V
- Charging current: ≤10A
- Discharging current: 50A
- Instant discharging current: 100A
- End-off voltage: 37.75V
- Internal resistance: ≤200mΩ
- Battery weight: 35Kg
- Product dimension: 420×265×140mm(Max)
- Discharging temperature: -20~55 ℃
FAQ
Q1: What applications are medical robot batteries designed for?
A: Medical robot batteries are used in applications such as rehabilitation robots, surgical robotic equipment, hospital logistics robots, and other mobile or electrically powered healthcare robotic systems. The battery must be matched to the robot’s voltage, runtime, load profile, available installation space, charging method, and control interface rather than selected by capacity alone.
Q2: How do I choose the right battery for a medical rehabilitation or surgical robot?
A: Start with the robot’s required voltage, usable capacity, continuous and peak current, target runtime, available battery space, weight limit, charging requirements, and communication interface. For medical rehabilitation and surgical robotic equipment, stable power delivery and predictable integration are especially important, so the battery should be engineered around the complete operating profile of the equipment.
Q3: Can FEBATT customize battery packs for medical robot manufacturers?
A: Yes. FEBATT can develop custom medical robot battery packs according to project requirements, including voltage, capacity, cell configuration, dimensions, housing, connector type, BMS settings, charging parameters, and communication interfaces. Customization is particularly useful when rehabilitation or surgical robots have restricted installation space or non-standard electrical requirements.
Q4: What battery chemistries are used for medical robot applications?
A: Rechargeable lithium-ion chemistries, including LiFePO4 and other lithium-ion configurations, can be used in medical robot applications. The appropriate chemistry depends on required energy density, cycle life, discharge performance, size, weight, and operating conditions. Chemistry should therefore be selected according to the specific medical robot design rather than treated as a one-size-fits-all choice.
Q5: How does the BMS protect a medical robot battery?
A: A Battery Management System (BMS) monitors key battery conditions such as voltage, current, and temperature and can provide protection against overcharge, over-discharge, overcurrent, short circuit, and abnormal temperature conditions. Depending on the battery configuration, the BMS may also support state-of-charge estimation, fault information, cell balancing, and communication with the robot controller.
Q6: What factors affect the service life of a medical robot battery?
A: Service life depends on battery chemistry, depth of discharge, charge and discharge rate, operating temperature, charging strategy, and the robot’s duty cycle. As a reference, selected FEBATT robot battery configurations are rated for 2,000+ cycles at 80% depth of discharge (DoD). The actual cycle-life rating for a medical robot battery should always be confirmed for the selected model and operating conditions.
Q7: How do continuous and peak current requirements affect battery selection?
A: Medical robots can have different power demands during movement, lifting, actuator operation, computing, or other peak-load events. The battery must provide sufficient continuous current for normal operation and adequate peak current for short-duration load increases without excessive voltage drop or protection shutdown. These current requirements should be defined during battery selection and matched to the BMS and cell configuration.
Q8: What communication interfaces can be integrated into medical robot batteries?
A: Depending on the project, medical robot battery systems can be configured with communication interfaces such as CAN or RS485 for data exchange with the robot controller. These interfaces can support information such as state of charge, voltage, current, temperature, and fault status. The required protocol, message format, and communication logic should be confirmed during system integration.
Q9: How do size and weight constraints affect medical robot battery design?
A: Size and weight can directly affect robot mobility, balance, enclosure design, and serviceability. FEBATT’s published medical robot battery examples include compact configurations such as 25.2V 2.9Ah as well as higher-capacity configurations such as 22.4V 50Ah, showing that battery architecture can vary substantially by application. A custom pack should be designed around the actual installation envelope and weight target of the robot.
Q10: What is the typical lead time for custom or bulk AGV robot battery orders?
A: Charging current, charger voltage, target runtime, duty cycle, allowable charging window, and whether the robot charges between operating periods should all be defined before the battery is finalized. For example, one published 48V 10Ah rehabilitation robot battery specifies a charge current of up to 5A and a 10A discharge current, illustrating why charging and load requirements must be matched to the individual battery model rather than assumed across the full product range.
Ready to Partner with FEBATT?
Join hundreds of B2B partners worldwide who trust us for reliable lithium battery solutions.